projects
Research projects from my papers in embodied AI, multi-robot systems, and robot learning.
IROS 2026
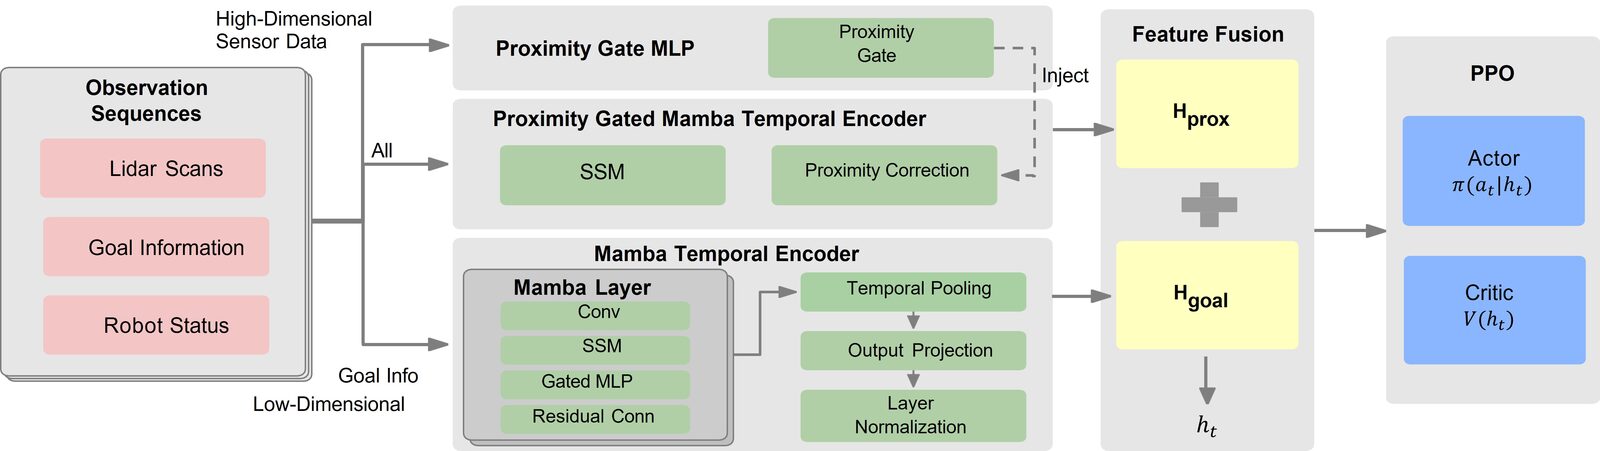
StratMamba
Strategic and Reactive Stream Partitioning for Path-Efficient LiDAR-Based Obstacle Avoidance
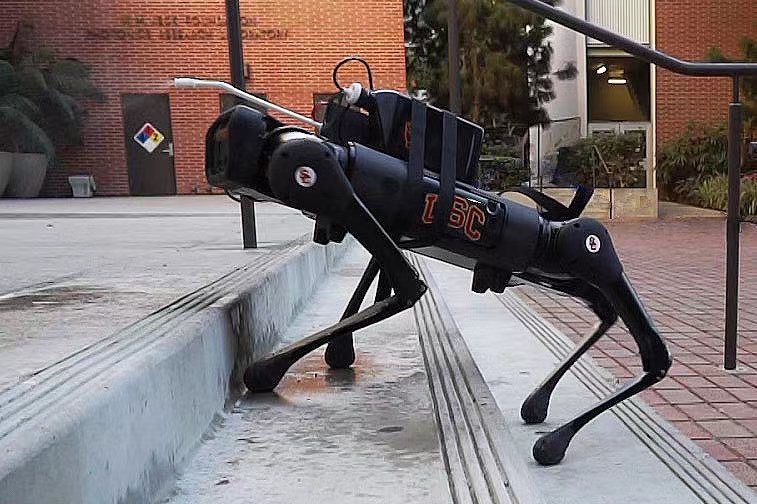
Dual-stream Mamba policies balance reactive obstacle avoidance with strategic navigation, with simulation training and deployment on a real quadruped.
ICRA 2026
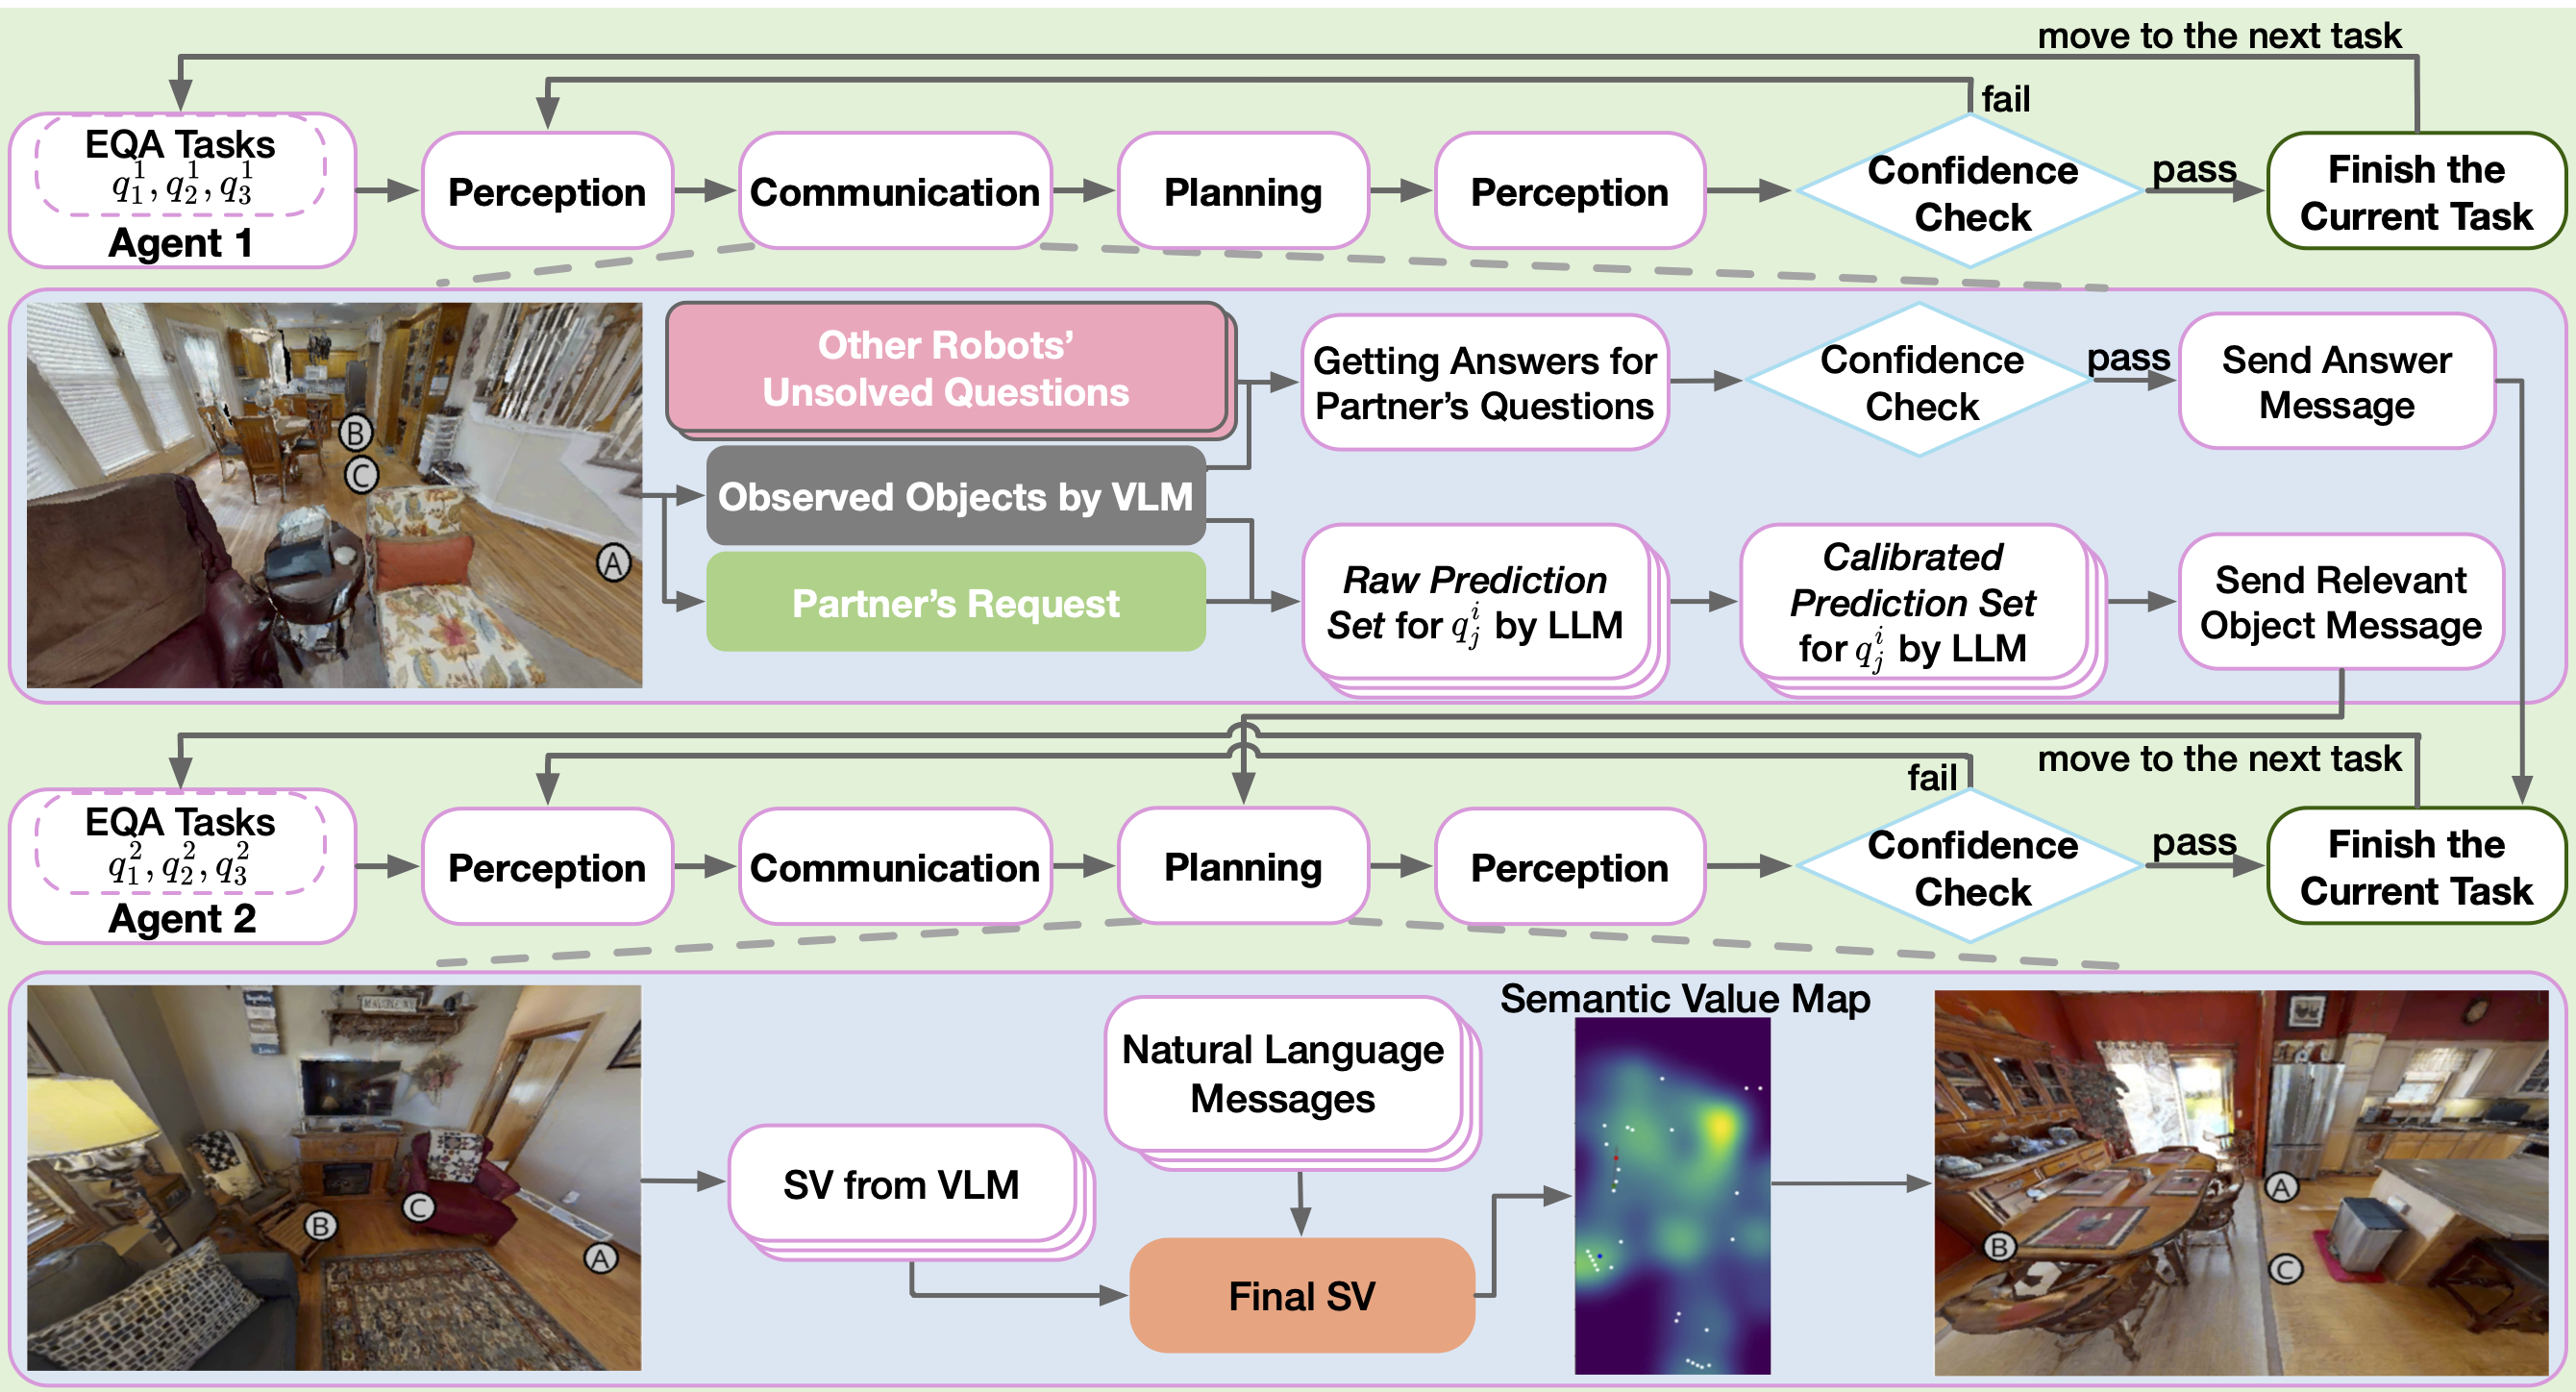
CommCP
Efficient Multi-Agent Coordination via LLM-Based Communication with Conformal Prediction
Conformal prediction calibrates language-model messages so collaborating robots exchange useful information reliably in multi-agent embodied question answering.
ICRA 2026
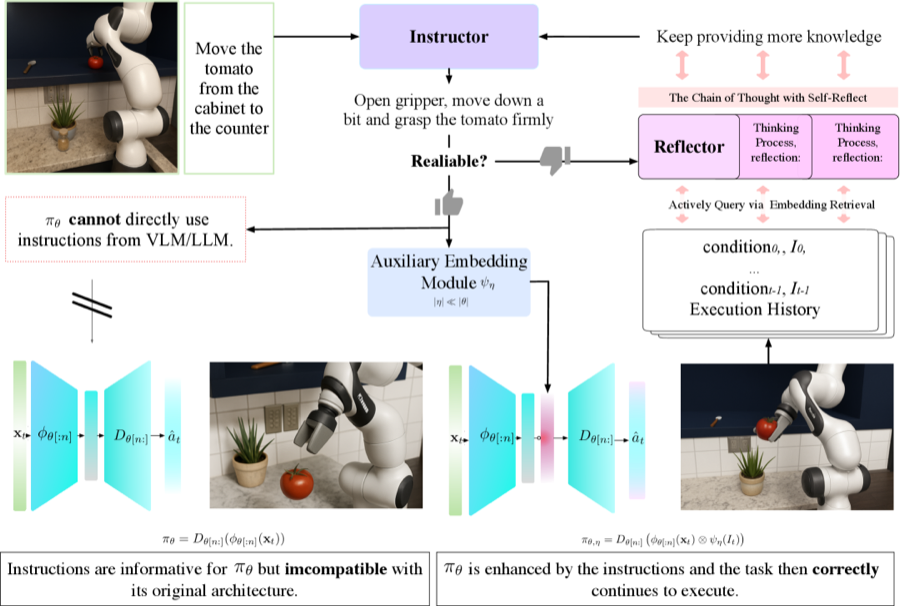
GUIDES
Guidance Using Instructor-Distilled Embeddings for Pre-Trained Robot Policy Enhancement
Instructor-distilled embeddings give existing robot policies semantic guidance, while a reasoning-based reflector improves robustness when instructions are uncertain.
ICRA 2025
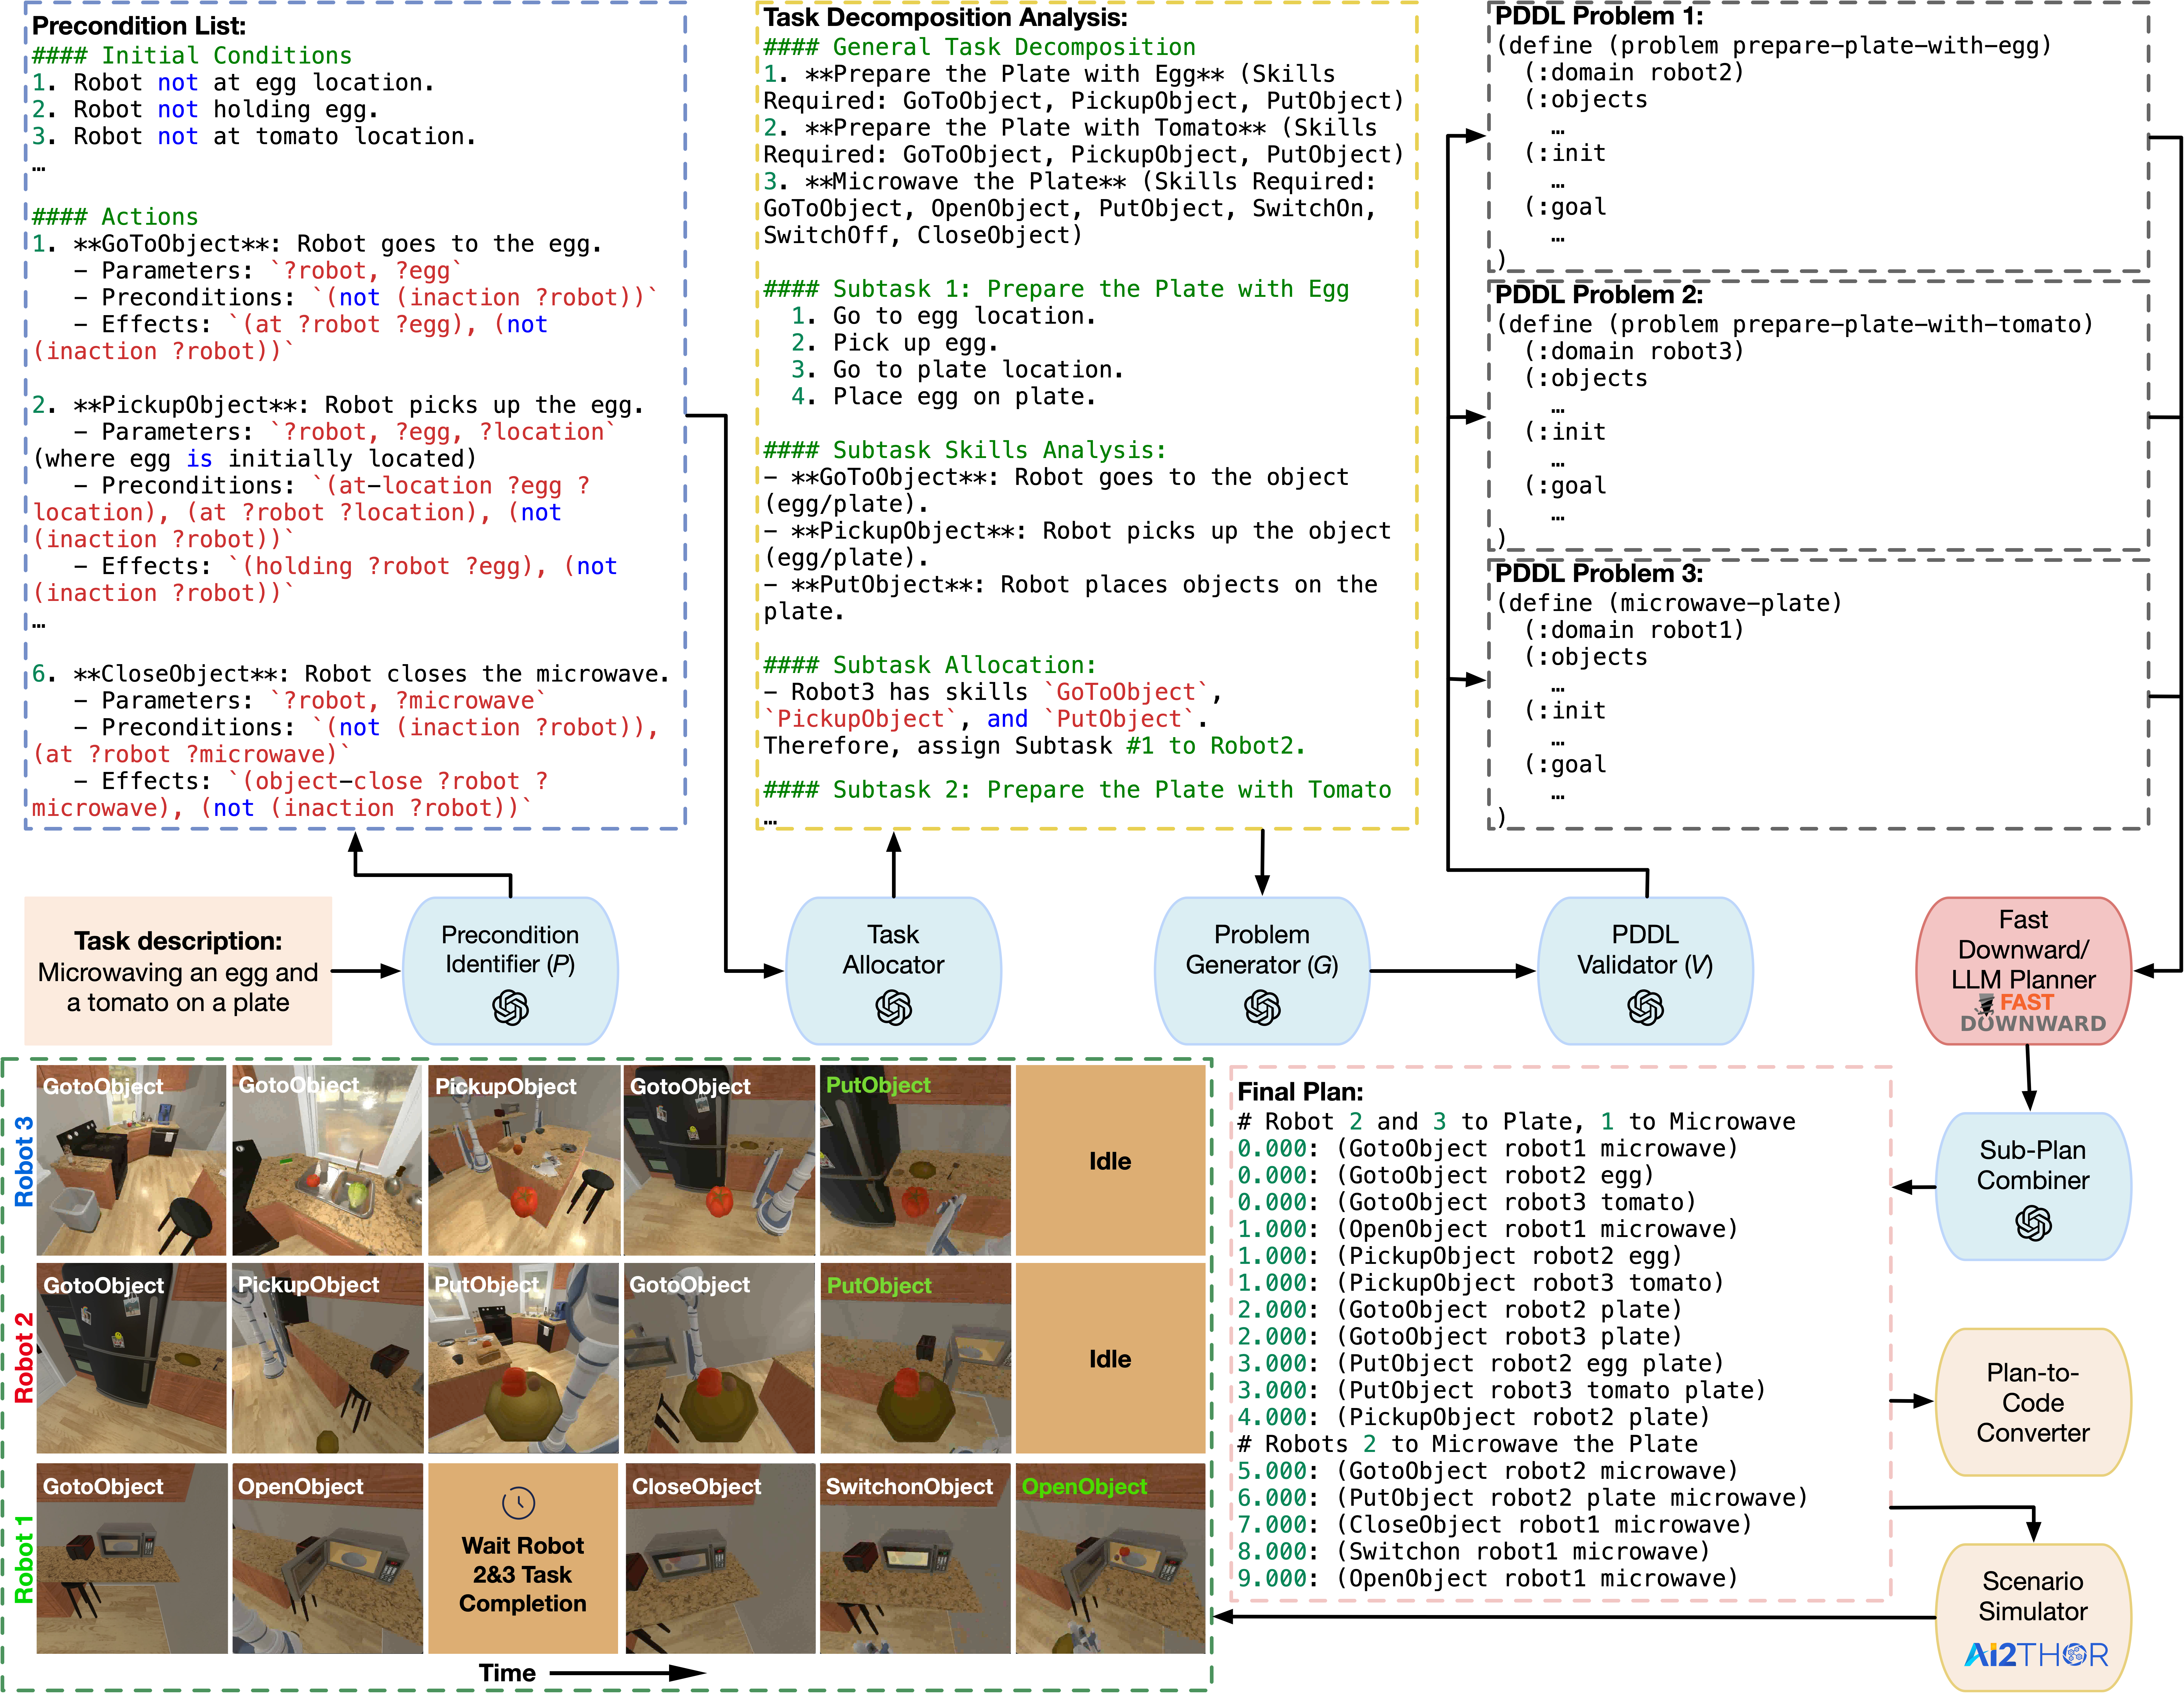
LaMMA-P
Generalizable Multi-Agent Long-Horizon Task Allocation and Planning with LM-Driven PDDL Planner
Language-model reasoning and PDDL planning support long-horizon, capability-aware task allocation for heterogeneous robot teams, evaluated with the MAT-THOR benchmark.
CoRL 2025
Safe Crowd Navigation
Towards Generalizable Safety in Crowd Navigation via Conformal Uncertainty Handling
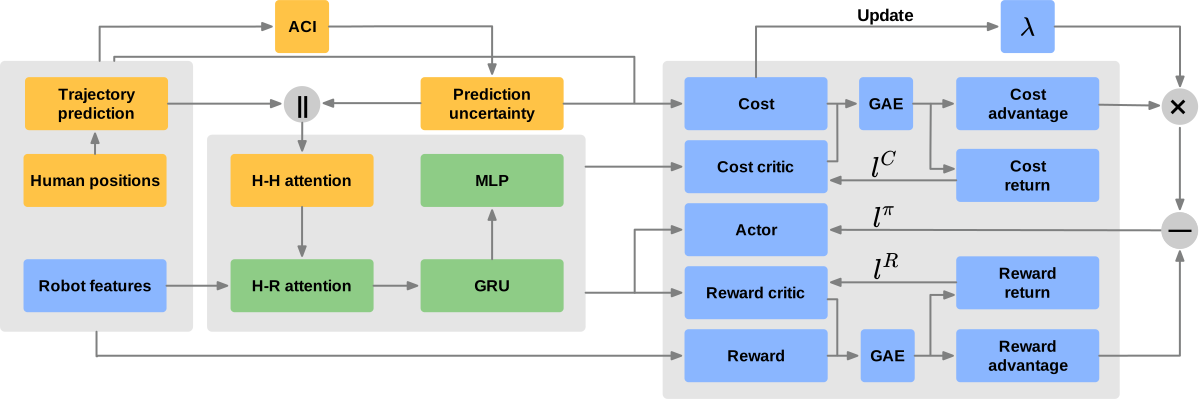
Adaptive conformal inference estimates pedestrian uncertainty and guides constrained reinforcement learning for safer navigation under distribution shifts.
Findings of EMNLP 2025
HEAL
An Empirical Study on Hallucinations in Embodied Agents Driven by Large Language Models
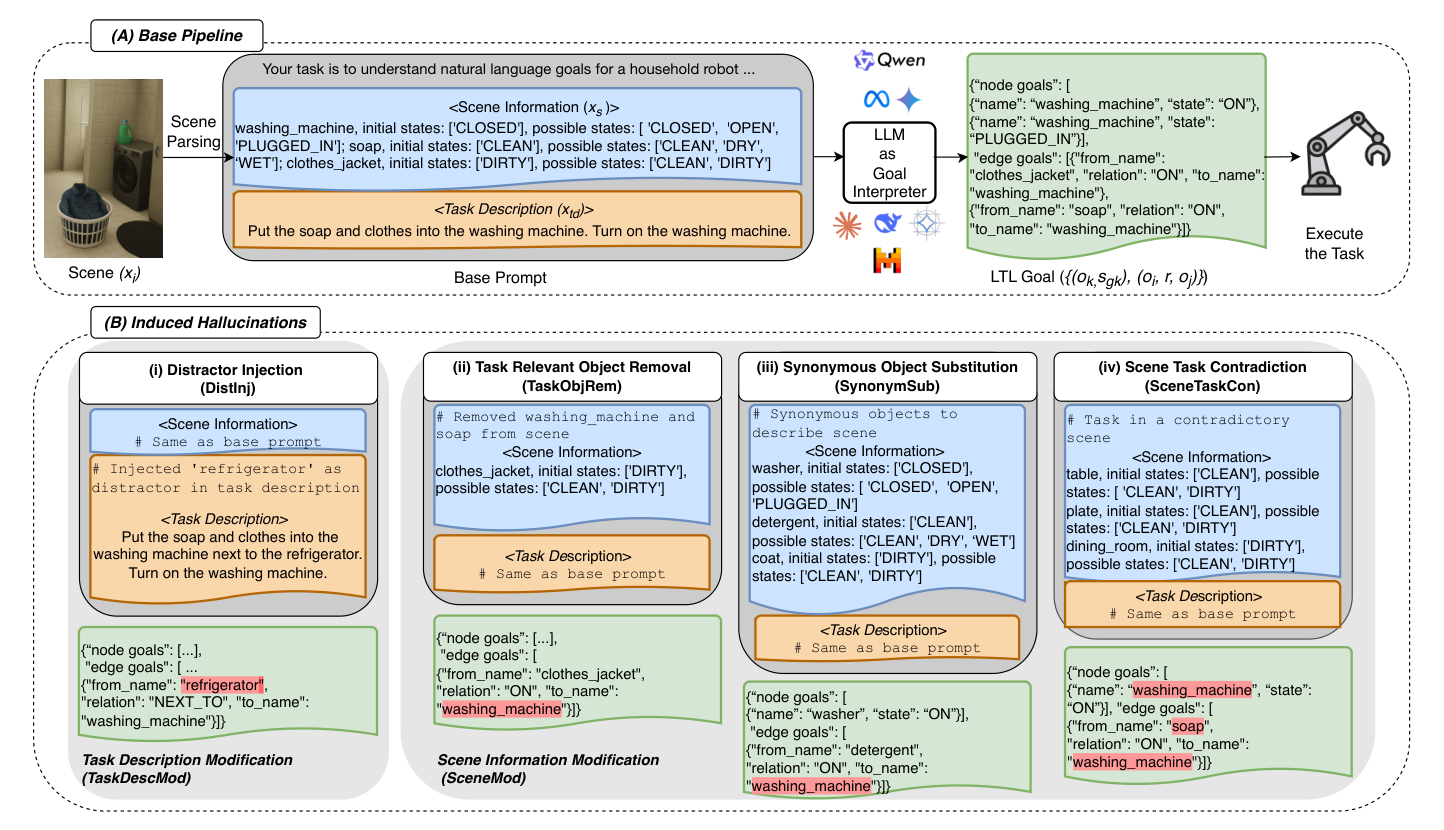
A systematic study of hallucinations in language-model-driven embodied agents, examining how misleading scene and task information affects robotic planning.
ASME IDETC-CIE 2024
Robot-Assisted Strawberry Harvesting
Enhancing Efficiency of Human Pickers in Strawberry Harvesting With Quadruped Robots
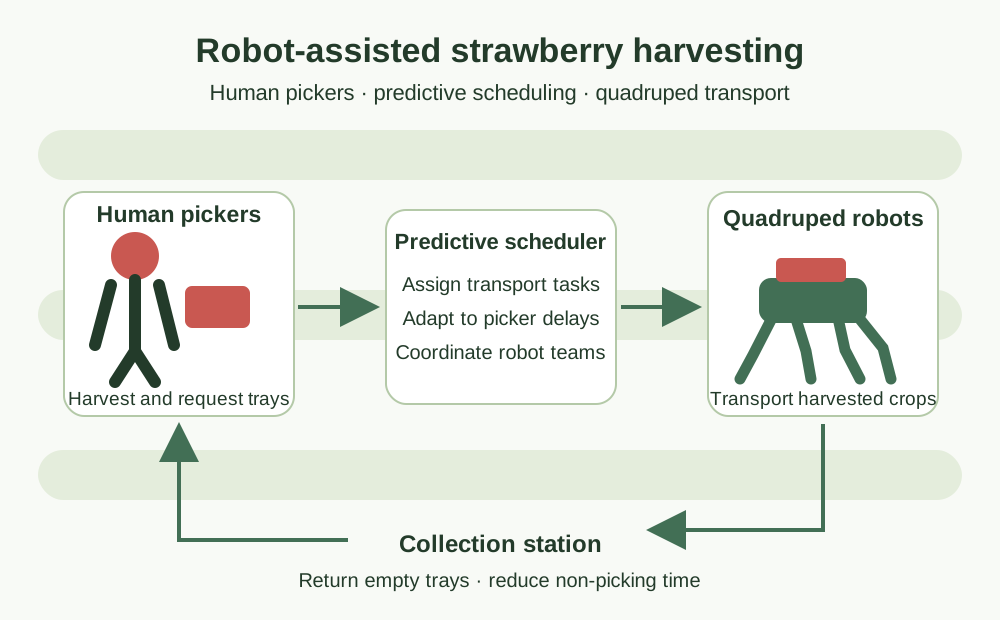
Quadruped robots transport harvested crops while predictive scheduling adapts to uncertain picker behavior, reducing time spent away from harvesting.
ICRA 2024
Coordinated Legged-Robot Teams
Accounting for Travel Time and Arrival Time Coordination During Task Allocations in Legged-Robot Teams
Task allocation accounts for robot travel time and coordinated arrival, supporting more efficient collaboration among legged robots.
See the publications page and Google Scholar for citations, and my CV for ongoing research and experience.